Drone Parts And Components Overview With DIY Tips

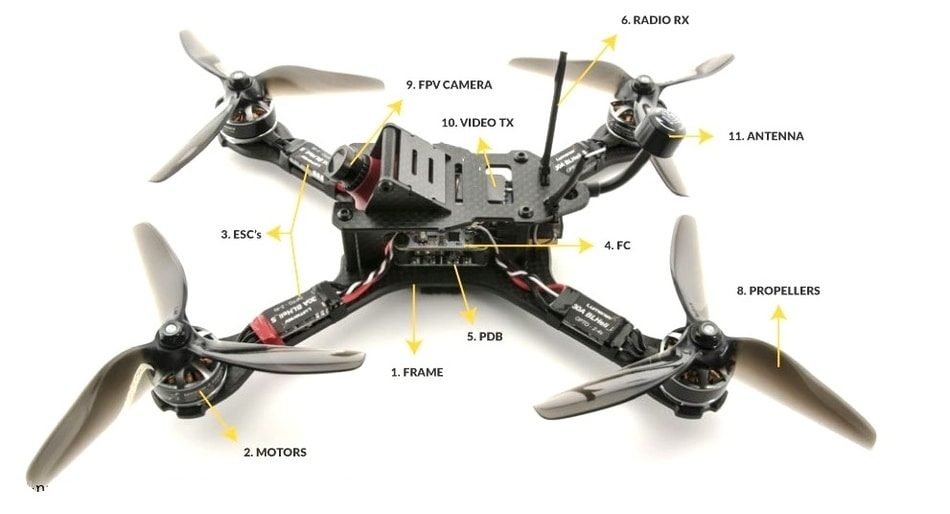
Every drone must be designed so that all components and parts are vital for a smooth and safe flight. Therefore, knowing the drone parts will help us understand how they operate and also give us an extra confidence during the flight. If something happens to our drone, we’ll understand much better which parts are essential and how to replace or upgrade them. Let’s go to see what are the main components that make up a modern drone.
What are the main parts of a drone?
Every multirotor is built from six systems: the frame, the propulsion system (motors, propellers and ESCs), the power system (LiPo battery and distribution), the flight controller with its IMU and GPS, the radio link (transmitter and receiver), and the payload — camera, gimbal or sensors. The signal chain runs in one direction: your stick input goes to the receiver, the flight controller decides what each motor should do, the ESCs deliver the current, and the propellers convert it into thrust. Consumer drones integrate all six into one sealed unit; custom builds keep them separate and replaceable.
Open up any multirotor — a folding camera drone, a racing quad, an agricultural sprayer — and you will find the same set of components doing the same jobs. The packaging changes enormously. The architecture barely changes at all.
That is genuinely useful to know, because it means understanding one drone means understanding all of them. This guide walks through every component in a modern drone: what it does, how the specifications are written, how to size it against the rest of the build, and what tends to break. It covers both the sealed consumer aircraft you buy in a box and the custom builds you assemble yourself.
The Six Core Systems of Any Drone
Before diving into individual parts, it helps to group them. Every multirotor is six systems working together, and every component belongs to one of them.
| System | Components | Job | Failure means |
|---|---|---|---|
| Structure | Frame, arms, landing gear, standoffs | Holds everything in fixed geometry | Vibration, then structural failure |
| Propulsion | Motors, propellers, ESCs | Converts electrical power into thrust | Loss of lift or control authority |
| Power | LiPo battery, PDB, wiring, connectors | Stores and distributes energy | Immediate loss of everything |
| Control | Flight controller, IMU, firmware | Decides what each motor does | Uncontrolled flight |
| Communication | Transmitter, receiver, antennas | Carries pilot commands and telemetry | Failsafe, then return to home |
| Payload | Camera, gimbal, sensors, VTX | Does the actual mission | Aircraft still flies, mission fails |

Notice the failure column. Only one system — payload — fails without ending the flight. That hierarchy is worth remembering when you are deciding where to spend money on a build.
The Frame: Structure and Materials
The frame holds the motors in a fixed geometry relative to each other and to the centre of mass. That sounds trivial and is not, because everything the flight controller does assumes the motors are exactly where the configuration says they are.
Frame stiffness matters more than frame strength. A flexible arm lets the motor twist slightly under load, which introduces vibration into the airframe, which contaminates the accelerometer readings, which degrades stabilisation. A frame that survives crashes but flexes in flight is a bad frame.
| Material | Stiffness | Weight | Cost | Typical use |
|---|---|---|---|---|
| Carbon fibre | Excellent | Very low | High | Racing, cinema, professional builds |
| Glass fibre | Good | Low | Moderate | Budget builds, trainer frames |
| Injection-moulded plastic | Moderate | Low | Very low | Consumer camera drones, toys |
| Aluminium | Good | Moderate | Moderate | Arms and clamps on large platforms |
| Magnesium alloy | Very good | Low | High | Premium consumer shells |
Carbon fibre has one drawback worth knowing: it blocks radio signals. That is why antennas on carbon-framed builds are routed outside the frame rather than tucked inside, and why GPS modules sit on a mast above the body rather than under a carbon plate.
Frames are sized by wheelbase, the diagonal motor-to-motor distance in millimetres, which in turn determines the largest propeller that fits.
| Class | Wheelbase | Propeller size | Typical role |
|---|---|---|---|
| Tiny whoop | 65–75 mm | 31–40 mm | Indoor flying |
| Toothpick / micro | 100–130 mm | 2–3 in | Lightweight outdoor |
| 5-inch freestyle / race | 210–250 mm | 5 in | FPV racing and freestyle |
| 7-inch long range | 290–320 mm | 7 in | Long-range cruising |
| Cinelifter / heavy | 450–900 mm | 10–18 in | Cinema cameras, heavy payload |
Brushless Motors: How to Read the Specification
Almost every drone above toy level uses brushless motors. Instead of physical brushes switching current, the ESC electronically energises stator coils in sequence, pulling permanent magnets in the rotating bell around with them.

Brushless motors last far longer than brushed ones because nothing rubs except the bearings, and they deliver much better power-to-weight. The trade-off is that they cannot run without an ESC.
Decoding the motor number
Motors are named with a four-digit code plus a KV rating — for example 2207 1900KV. Both halves matter.
| Part of the code | Meaning | Effect |
|---|---|---|
| First two digits (22) | Stator diameter in mm | Wider stator produces more torque |
| Last two digits (07) | Stator height in mm | Taller stator adds torque and weight |
| KV rating (1900KV) | RPM per volt with no load | Higher KV spins faster with less torque |
The KV Formula
Unloaded RPM = KV × Battery voltage
A 1900KV motor on a fully charged 4S pack (16.8 V) spins at roughly 31,900 rpm with no propeller fitted. Under load with a propeller attached, actual rpm is substantially lower.
The relationship people get wrong is that high KV does not mean more powerful. KV describes the speed-versus-torque trade-off, not the total power. A high-KV motor spins a small propeller very fast; a low-KV motor turns a large propeller more slowly. Both can produce identical thrust, but the low-KV and large-propeller combination is significantly more efficient, which is why long-endurance camera drones use big, slow props and racing quads use small, fast ones.

| Battery | Typical KV range | Propeller size | Character |
|---|---|---|---|
| 2S–3S | 3,000–8,000KV | 2–3 in | Micro builds, indoor |
| 4S | 2,300–2,700KV | 5 in | Punchy, responsive |
| 6S | 1,500–1,900KV | 5 in | Efficient, less current draw |
| 6S | 1,100–1,400KV | 7 in | Long range cruising |
| 6S–12S | Under 500KV | 10 in and larger | Heavy lift, cinema |
Propellers: Diameter, Pitch and Blade Count
The propeller is the part that actually produces thrust, and it is also the cheapest part on the aircraft and the one that fails most often.
Propeller codes look like 5045 or 5×4.5×3. The first number is diameter in inches, the second is pitch in inches, and a third number if present is blade count.
| Property | Increase it and you get | Cost |
|---|---|---|
| Diameter | More thrust, better efficiency, more stability | Slower response, needs a larger frame and lower KV |
| Pitch | Higher top speed, more air moved per rotation | Much higher current draw, more heat |
| Blade count | More grip and smoother response | Lower efficiency, shorter flight time |
Pitch is the theoretical distance the propeller would travel forward in one rotation if the air were solid. High pitch is the aggressive option: more speed, dramatically more current, hotter motors. Two-blade propellers are the efficiency choice; three-blade props trade flight time for smoothness and grip, which is why they dominate freestyle flying.
Electronic Speed Controllers (ESCs)
The ESC sits between the battery and the motor. It takes a low-power signal from the flight controller and converts DC battery power into the three-phase switching sequence a brushless motor needs. Every motor requires its own ESC.

ESCs are rated in continuous amps, and that rating must exceed the maximum current the motor can draw. Undersize it and the ESC overheats and fails — usually at full throttle, which is the worst possible moment.
Sizing an ESC
ESC rating ≥ Max motor current × 1.2
If your motor draws a peak of 30 A on the chosen propeller, fit a 35 A or 40 A ESC. Headroom costs a few grams and prevents the most common electrical failure in drone building.
| ESC feature | What it means | Why it matters |
|---|---|---|
| Continuous amp rating | Sustained current it can handle | The number you size against |
| Burst rating | Short peak tolerance, a few seconds | Never design around this figure |
| Voltage rating (e.g. 3–6S) | Battery cell counts supported | Exceeding it destroys the ESC instantly |
| Firmware (BLHeli_32, AM32) | Motor control software | Determines protocol support and features |
| Protocol (DShot600 and similar) | Digital signalling from the FC | Digital is faster and more precise than analogue PWM |
| 4-in-1 vs individual | One combined board or four separate | 4-in-1 is tidier, individual ESCs are easier to replace |
| BEC | Built-in voltage regulator | Powers the receiver and flight controller |
Matching Motors, Propellers and ESCs
These three components are one system, and mismatching them is the most common mistake in first builds. The interaction runs in a chain: propeller size and pitch determine motor current draw, motor current determines the ESC rating you need, and total current determines the battery C rating required.
| Mismatch | What happens |
|---|---|
| Propeller too large for the motor | Motor overheats, magnets can demagnetise permanently |
| KV too high for the propeller | Enormous current draw, very short flight time |
| ESC underrated for the motor | ESC overheats and fails at full throttle |
| Battery C rating too low | Voltage sag, weak throttle response, damaged pack |
| Motors too weak for the airframe | Hovering above 60% throttle, no control margin |
The practical shortcut: motor manufacturers publish thrust data tables for their motors on specific propellers and cell counts, listing thrust, current and efficiency at each throttle level. Use those tables rather than guessing. They are the difference between a build that works and one that melts.
Batteries and Power Distribution
Almost every drone runs on lithium polymer. LiPo packs deliver very high current for their weight, which is exactly what motors need, and they are also the least forgiving component on the aircraft.
A pack labelled 4S 1500mAh 100C tells you everything you need.
| Label | Meaning | Effect |
|---|---|---|
| 4S | Four cells in series | 14.8 V nominal, 16.8 V fully charged |
| 1500mAh | Capacity, 1.5 amp-hours | More capacity means longer flight and more weight |
| 100C | Discharge rate multiplier | Maximum safe continuous current draw |
| P (as in 2P) | Cells in parallel | Increases capacity, not voltage |
Maximum Continuous Discharge
Max current (A) = Capacity (Ah) × C rating
A 1500 mAh (1.5 Ah) pack rated 100C can theoretically supply 150 A continuously. Manufacturer C ratings are frequently optimistic, so treat roughly 70% of the claimed figure as the realistic working limit.
| Voltage per cell | State | Action |
|---|---|---|
| 4.20 V | Fully charged | Fly now, do not store at this level |
| 3.80 V | Storage charge | Correct level for storing more than a few days |
| 3.70 V | Nominal | The figure used in specifications |
| 3.50 V under load | Land now | Set your low-voltage alarm here |
| Below 3.30 V | Over-discharged | Permanent capacity loss, possible damage |
Two supporting components complete the power system. The power distribution board splits battery power out to each ESC and to the electronics, often with voltage regulators supplying 5 V and 9 V rails. On modern builds this is usually integrated into a 4-in-1 ESC. Connectors matter too: XT30, XT60 and XT90 are rated for progressively higher current, and using a connector below the current your build draws creates a hot spot that eventually fails.
The Flight Controller and Its Firmware
The flight controller is the computer that turns your intentions into motor commands. It carries a microcontroller, the IMU with gyroscope and accelerometer, a barometer, and connections to every other subsystem.

How the flight controller is mounted matters as much as which one you buy. Boards are fitted on soft rubber grommets specifically to isolate them from frame vibration, because vibration reaching the accelerometer produces false attitude readings. A rigidly bolted flight controller will fly badly regardless of its specification.
| Firmware | Best for | Character |
|---|---|---|
| Betaflight | FPV racing and freestyle | Highly tunable, responsive, manual-flight focused |
| INAV | Long range and navigation | GPS features, waypoints, return to home |
| ArduPilot | Autonomous and commercial work | Extremely capable, steep learning curve |
| PX4 | Research and industry | Open architecture, strong developer ecosystem |
| Manufacturer firmware | Consumer camera drones | Closed, tuned at the factory, not user-modifiable |
On a consumer drone all of this is sealed and invisible. On a custom build, the flight controller plus a 4-in-1 ESC is referred to as a “stack” — two boards bolted together in the centre of the frame.
The Radio Control System
The radio link carries your stick inputs to the aircraft and telemetry back to you. It consists of a transmitter in your hands, a receiver on the drone, and antennas at both ends.

Control links are separate from video links. They run at lower data rates and higher reliability, because a dropped video frame is an annoyance while a dropped control packet is an emergency.
| Link type | Frequency | Strength | Typical use |
|---|---|---|---|
| Basic 2.4 GHz | 2.4 GHz | Cheap, adequate close range | Toys, trainers |
| ExpressLRS | 2.4 GHz or 900 MHz | Very long range, low latency, open source | FPV builds of all sizes |
| Crossfire | 900 MHz | Excellent penetration through obstacles | Long-range FPV |
| Manufacturer systems | 2.4 and 5.8 GHz | Integrated control plus HD video | Consumer camera drones |
One point on antennas that costs nothing to fix: transmitter antennas are directional. The radiation pattern is strongest broadside and weakest off the tip, so pointing the antenna tips straight at your drone aims the weakest part of the signal at it. Keep the flat faces toward the aircraft.
FPV and Video Components
First-person view adds three components: a camera dedicated to the pilot’s view, a video transmitter (VTX), and antennas.

| Analogue FPV | Digital FPV | |
|---|---|---|
| Image quality | Low resolution, noisy | HD, sharp |
| Latency | Extremely low | Low, slightly higher than analogue |
| Signal degradation | Gradual static, always usable | Sharp cliff at the edge of range |
| Cost | Low | High |
| Best for | Racing, cheap builds, crash-prone flying | Cinematic FPV, general flying |
The failure behaviour in row three is the reason analogue survives. Analogue video degrades into static gradually, so a pilot can still make out enough to fly home. Digital systems hold a perfect picture until they do not, and then you have nothing.
VTX output power is measured in milliwatts and is legally restricted in many countries. Note also that circular polarised antennas are standard on video systems because they reject reflected signals — a genuine problem when flying near buildings and trees.
Navigation and Sensor Components
| Sensor | Measures | Enables |
|---|---|---|
| GNSS module (GPS, GLONASS, Galileo) | Absolute position | Position hold, return to home, waypoints |
| Magnetometer / compass | Magnetic heading | Knowing which way the aircraft faces |
| Barometer | Air pressure | Altitude hold |
| Downward rangefinder | Height above ground | Precise low-altitude hold and landing |
| Optical flow camera | Ground movement | Indoor position hold without GPS |
| Obstacle sensors | Distance to objects | Collision avoidance |
| RTK module | Centimetre-level position | Survey and mapping accuracy |
The compass deserves a note because it causes more field problems than the rest combined. It measures a weak magnetic field and is easily disturbed by power wiring, steel structures, reinforced concrete and vehicles. That is why GPS and compass modules sit on masts, away from the high-current wiring, and why compass calibration is location-dependent while IMU calibration is not.
Camera and Gimbal
The gimbal is a separate stabilisation system with its own IMU and its own brushless motors, working independently of the flight controller.
| Type | Axes stabilised | Result |
|---|---|---|
| Fixed mount | None | Camera moves with the airframe |
| 2-axis gimbal | Pitch and roll | Level horizon, some yaw movement visible |
| 3-axis gimbal | Pitch, roll and yaw | Fully isolated, smooth footage in every direction |
This is why a camera drone can bank hard into a turn while the horizon in the footage stays perfectly level: the airframe rotates, the gimbal counter-rotates by the same amount, and the sensor never knows the aircraft moved.
How All the Parts Work Together
The components only make sense once you follow a single stick movement through the whole system.
The Signal Chain, Start to Finish
- You move a stick. The transmitter encodes the position and broadcasts it.
- The receiver on the aircraft decodes the packet and passes it to the flight controller.
- The flight controller compares your requested attitude with what the IMU reports the aircraft is actually doing.
- The control loop calculates the error and works out a correction for each of the four motors.
- Digital signals go out to the four ESCs, hundreds of times per second.
- Each ESC draws current from the battery and switches it through the motor’s three phases at the commanded rate.
- Each motor spins its propeller at a slightly different speed from its neighbours.
- The propellers produce differential thrust, tilting the aircraft, and it moves.
- The IMU measures the result, and the loop starts again.
The critical insight is in step three. You are never commanding a motor. You are requesting an attitude, and an algorithm is deciding what four rpm values will produce it. That is why a single bad sensor reading affects everything downstream, and why calibration matters so much.
Build Formulas and Component Sizing
If you are specifying components rather than buying a finished aircraft, these are the calculations that decide whether the build works.
The Five Formulas
1. Unloaded RPM = KV × Voltage
2. Max battery current (A) = Capacity (Ah) × C rating
3. Required total thrust = All-up weight × 2
4. Thrust per motor = (AUW × 2) ÷ Number of motors
5. ESC rating ≥ Max motor current × 1.2
Estimating Flight Time
Flight time (min) ≈ (Capacity in Ah × 0.8 × 60) ÷ Average current (A)
The 0.8 factor accounts for the 20% reserve you should never discharge. A 1.5 Ah pack drawing an average of 20 A gives roughly (1.5 × 0.8 × 60) ÷ 20 = 3.6 minutes, which is exactly why 5-inch FPV quads have such short flights.
Worked Build Example
- Target all-up weight: 700 g including battery.
- Required total thrust: 700 × 2 = 1,400 g.
- Per motor: 1,400 ÷ 4 = 350 g minimum. Choose motors rated well above this on your chosen prop.
- Motor peak current: the manufacturer’s thrust table shows 28 A on that propeller at 4S.
- ESC sizing: 28 × 1.2 = 33.6 A, so fit 35 A or 40 A ESCs.
- Battery requirement: four motors at 28 A is 112 A peak, so a 1500 mAh pack needs at least 75C real-world capability.
Consumer Drones vs Custom Builds
| Consumer camera drone | Custom build | |
|---|---|---|
| Frame | Moulded shell, integrated | Separate carbon plates and arms |
| ESCs | Sealed inside, not serviceable | Replaceable individually or as a 4-in-1 |
| Flight controller | Proprietary, locked firmware | Open firmware, fully tunable |
| Battery | Smart pack with its own firmware | Standard LiPo, any compatible pack |
| Repairability | Props and occasionally motors | Every component individually |
| Tuning | Factory only | Full PID and rate control |
| Setup effort | Minutes out of the box | Hours, plus soldering |
Neither approach is better in general terms. Consumer drones deliver excellent results immediately and are essentially disposable at component level. Custom builds cost more time and knowledge but can be repaired indefinitely and tuned to a specific job.
Which Drone Parts Fail First?
| Component | Failure frequency | Warning sign |
|---|---|---|
| Propellers | Very high | Chips, cracks, new vibration in footage |
| Battery | High, wears with cycles | Puffing, faster voltage sag, reduced flight time |
| Motor bearings | Moderate | Grinding or roughness when spun by hand |
| ESCs | Moderate | One motor cutting out, burnt smell |
| Frame arms | Crash dependent | Visible cracks, flex under load |
| Gimbal ribbon cable | Low but awkward | Intermittent camera feed, gimbal errors |
| Flight controller | Low | Usually only after crash or water damage |
Component Mistakes Worth Avoiding
- Undersizing the ESC. Always add at least 20% headroom over peak motor current.
- Trusting the printed C rating. Assume roughly 70% of the claimed figure in practice.
- Rigidly mounting the flight controller. Soft mounts exist because vibration corrupts the IMU.
- Flying damaged propellers. The cheapest part causes the most expensive symptoms.
- Storing LiPos fully charged. Store at 3.8 V per cell to preserve capacity.
- Mounting GPS near power wiring. Magnetic interference makes the compass useless.
- Using undersized connectors. A connector below your build’s current draw becomes a hot spot.
- Ignoring published thrust tables. Manufacturers measured this so you do not have to guess.
The pattern across all of it is that drones are systems rather than collections of parts. A perfectly good motor performs badly on the wrong propeller. A high-end flight controller flies badly if it is mounted rigidly. An expensive battery sags if its connector is undersized. Choosing components in isolation is the single most reliable way to build a disappointing aircraft — and understanding how they interact is what separates a build that works from one that merely flies.
Frequently Asked Questions
Six systems: the frame, the propulsion system (motors, propellers, ESCs), the power system (battery and distribution), the flight controller with its IMU, the radio link (transmitter and receiver), and the payload such as a camera or sensors. Only the payload can fail without ending the flight.
KV is revolutions per minute per volt with no propeller fitted. A 1900KV motor on a fully charged 4S pack at 16.8 V spins at roughly 31,900 rpm unloaded. High KV means faster rotation with less torque, not more power.
The first two digits are the stator diameter in millimetres and the last two are the stator height. So 2207 means a 22 mm wide, 7 mm tall stator. A larger stator produces more torque, which is what lets a motor swing a bigger propeller.
Five inches of diameter and 4.5 inches of pitch. Pitch is the theoretical distance the prop would advance in one rotation through a solid medium. A third number, as in 5×4.5×3, indicates blade count.
Take the peak current your motor draws on your chosen propeller from the manufacturer’s thrust table, and multiply by 1.2 for headroom. A motor peaking at 30 A needs a 35 A or 40 A ESC. Never size against the ESC’s burst rating.
Four cells in series giving 14.8 V nominal and 16.8 V charged, 1500 milliamp-hours of capacity, and a 100C discharge rating. Multiply capacity in amp-hours by the C rating for maximum continuous current: 1.5 × 100 = 150 A in theory, though roughly 70% is realistic.
Multiply battery capacity in amp-hours by 0.8 for the reserve, multiply by 60 for minutes, then divide by average current draw. A 1.5 Ah pack drawing 20 A gives roughly 3.6 minutes, which is why 5-inch FPV quads have such short flights.
Analogue is lower resolution but degrades gradually into static, so you can usually still fly home at the edge of range. Digital gives an HD picture but drops off a cliff — perfect image until suddenly nothing. That failure behaviour is why racers still use analogue.
To isolate the IMU from frame vibration. Vibration looks like acceleration to the accelerometer, which corrupts the attitude estimate and makes the drone fly at a slight permanent angle. A rigidly bolted flight controller flies badly regardless of its specification.
Propellers, by a wide margin. They are also the cheapest part and the one that causes the most expensive symptoms, since a chipped blade feeds vibration into the IMU and produces drift that recalibration will not fix. Batteries are second, wearing out with charge cycles.
Related Article: How A Quadcopter Works Along With Propellers And Motors
